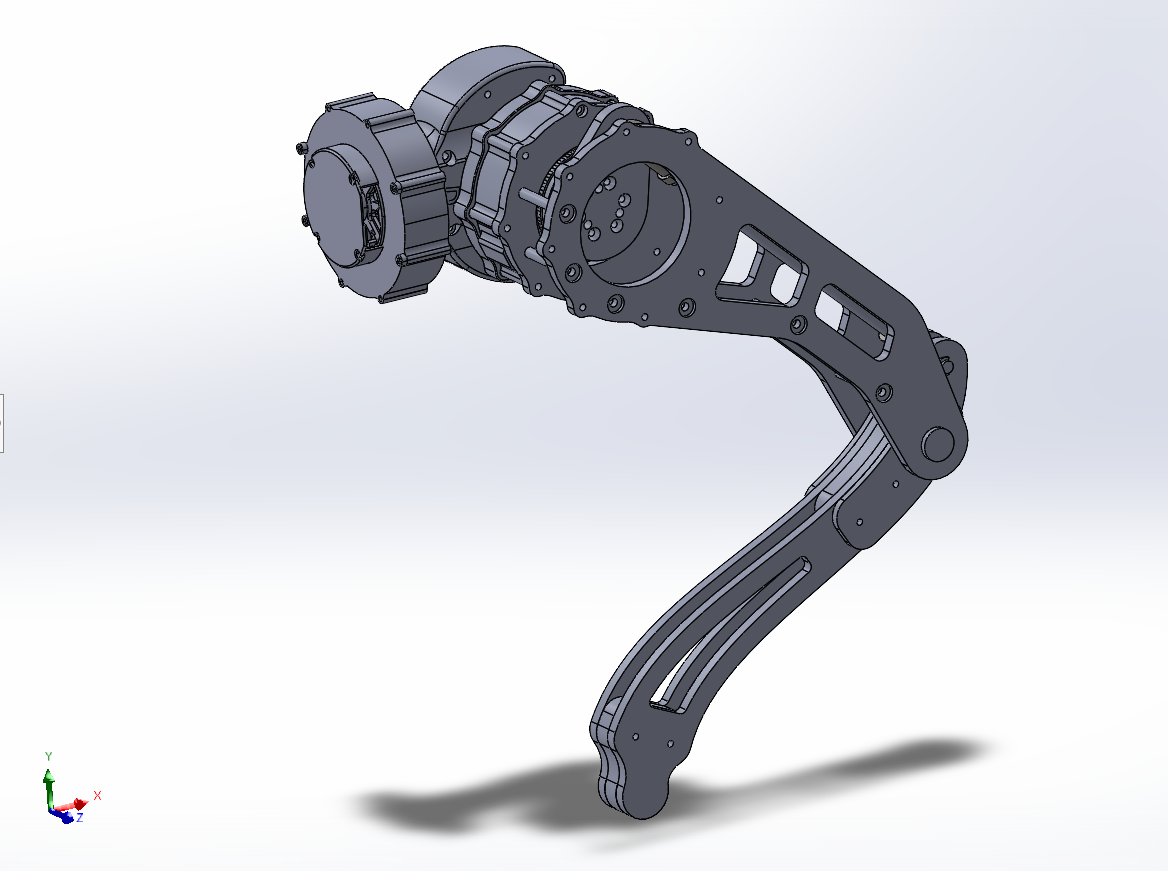
For my final-year project I'm the mechanical lead on a quadruped with an integrated arm, built to collect office garbage. My focus is the leg.
I designed the mechanical leg end-to-end in SolidWorks — the single-leg assembly, the hip and knee joints, and a gear-linkage knee drive that follows the Go2 Air architecture. Mass stays up at the body (MIT Cheetah style), so the lower leg carries no motor and the swing inertia stays low.
I worked the actuator sizing out by hand: a ~1.2 m/s gait needs about 95 RPM at the joints, and the chosen module (GIM8108-8, 22 N·m peak, 8:1) covers it with margin. The design is now moving from 3D-printed and laser-cut validation parts to CNC for the load path.
The leg is designed and the sizing is done. Next: machine it, then get it walking.