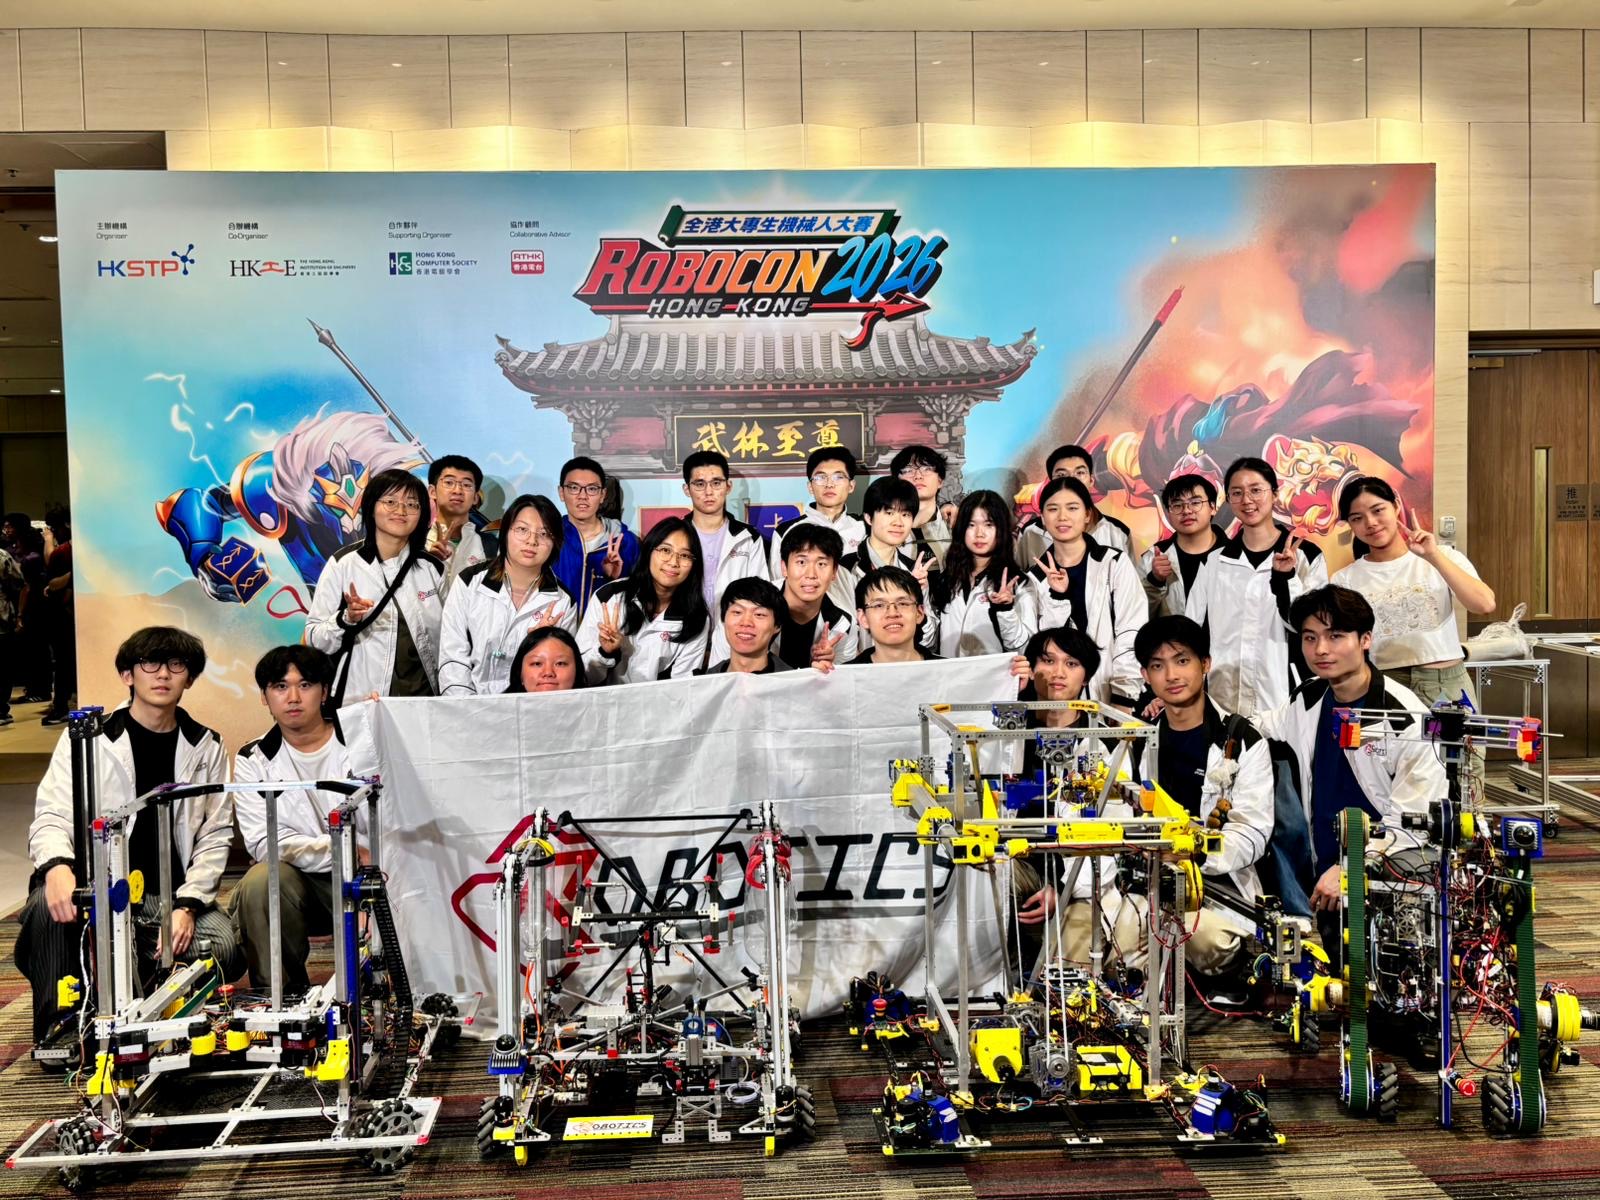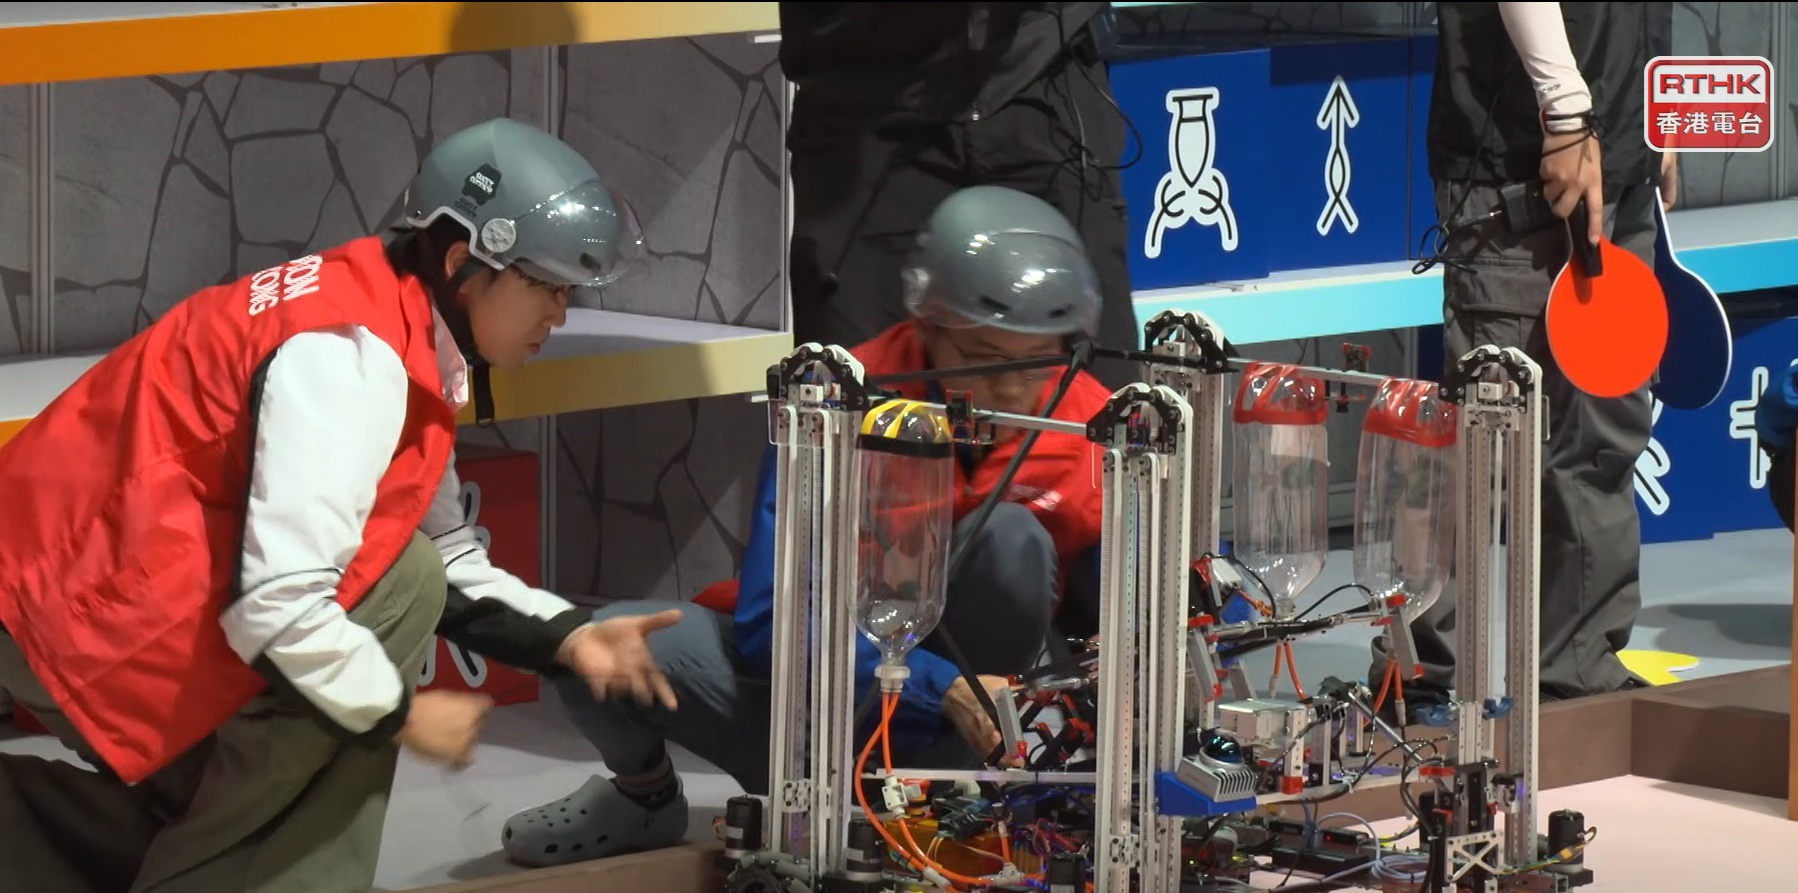
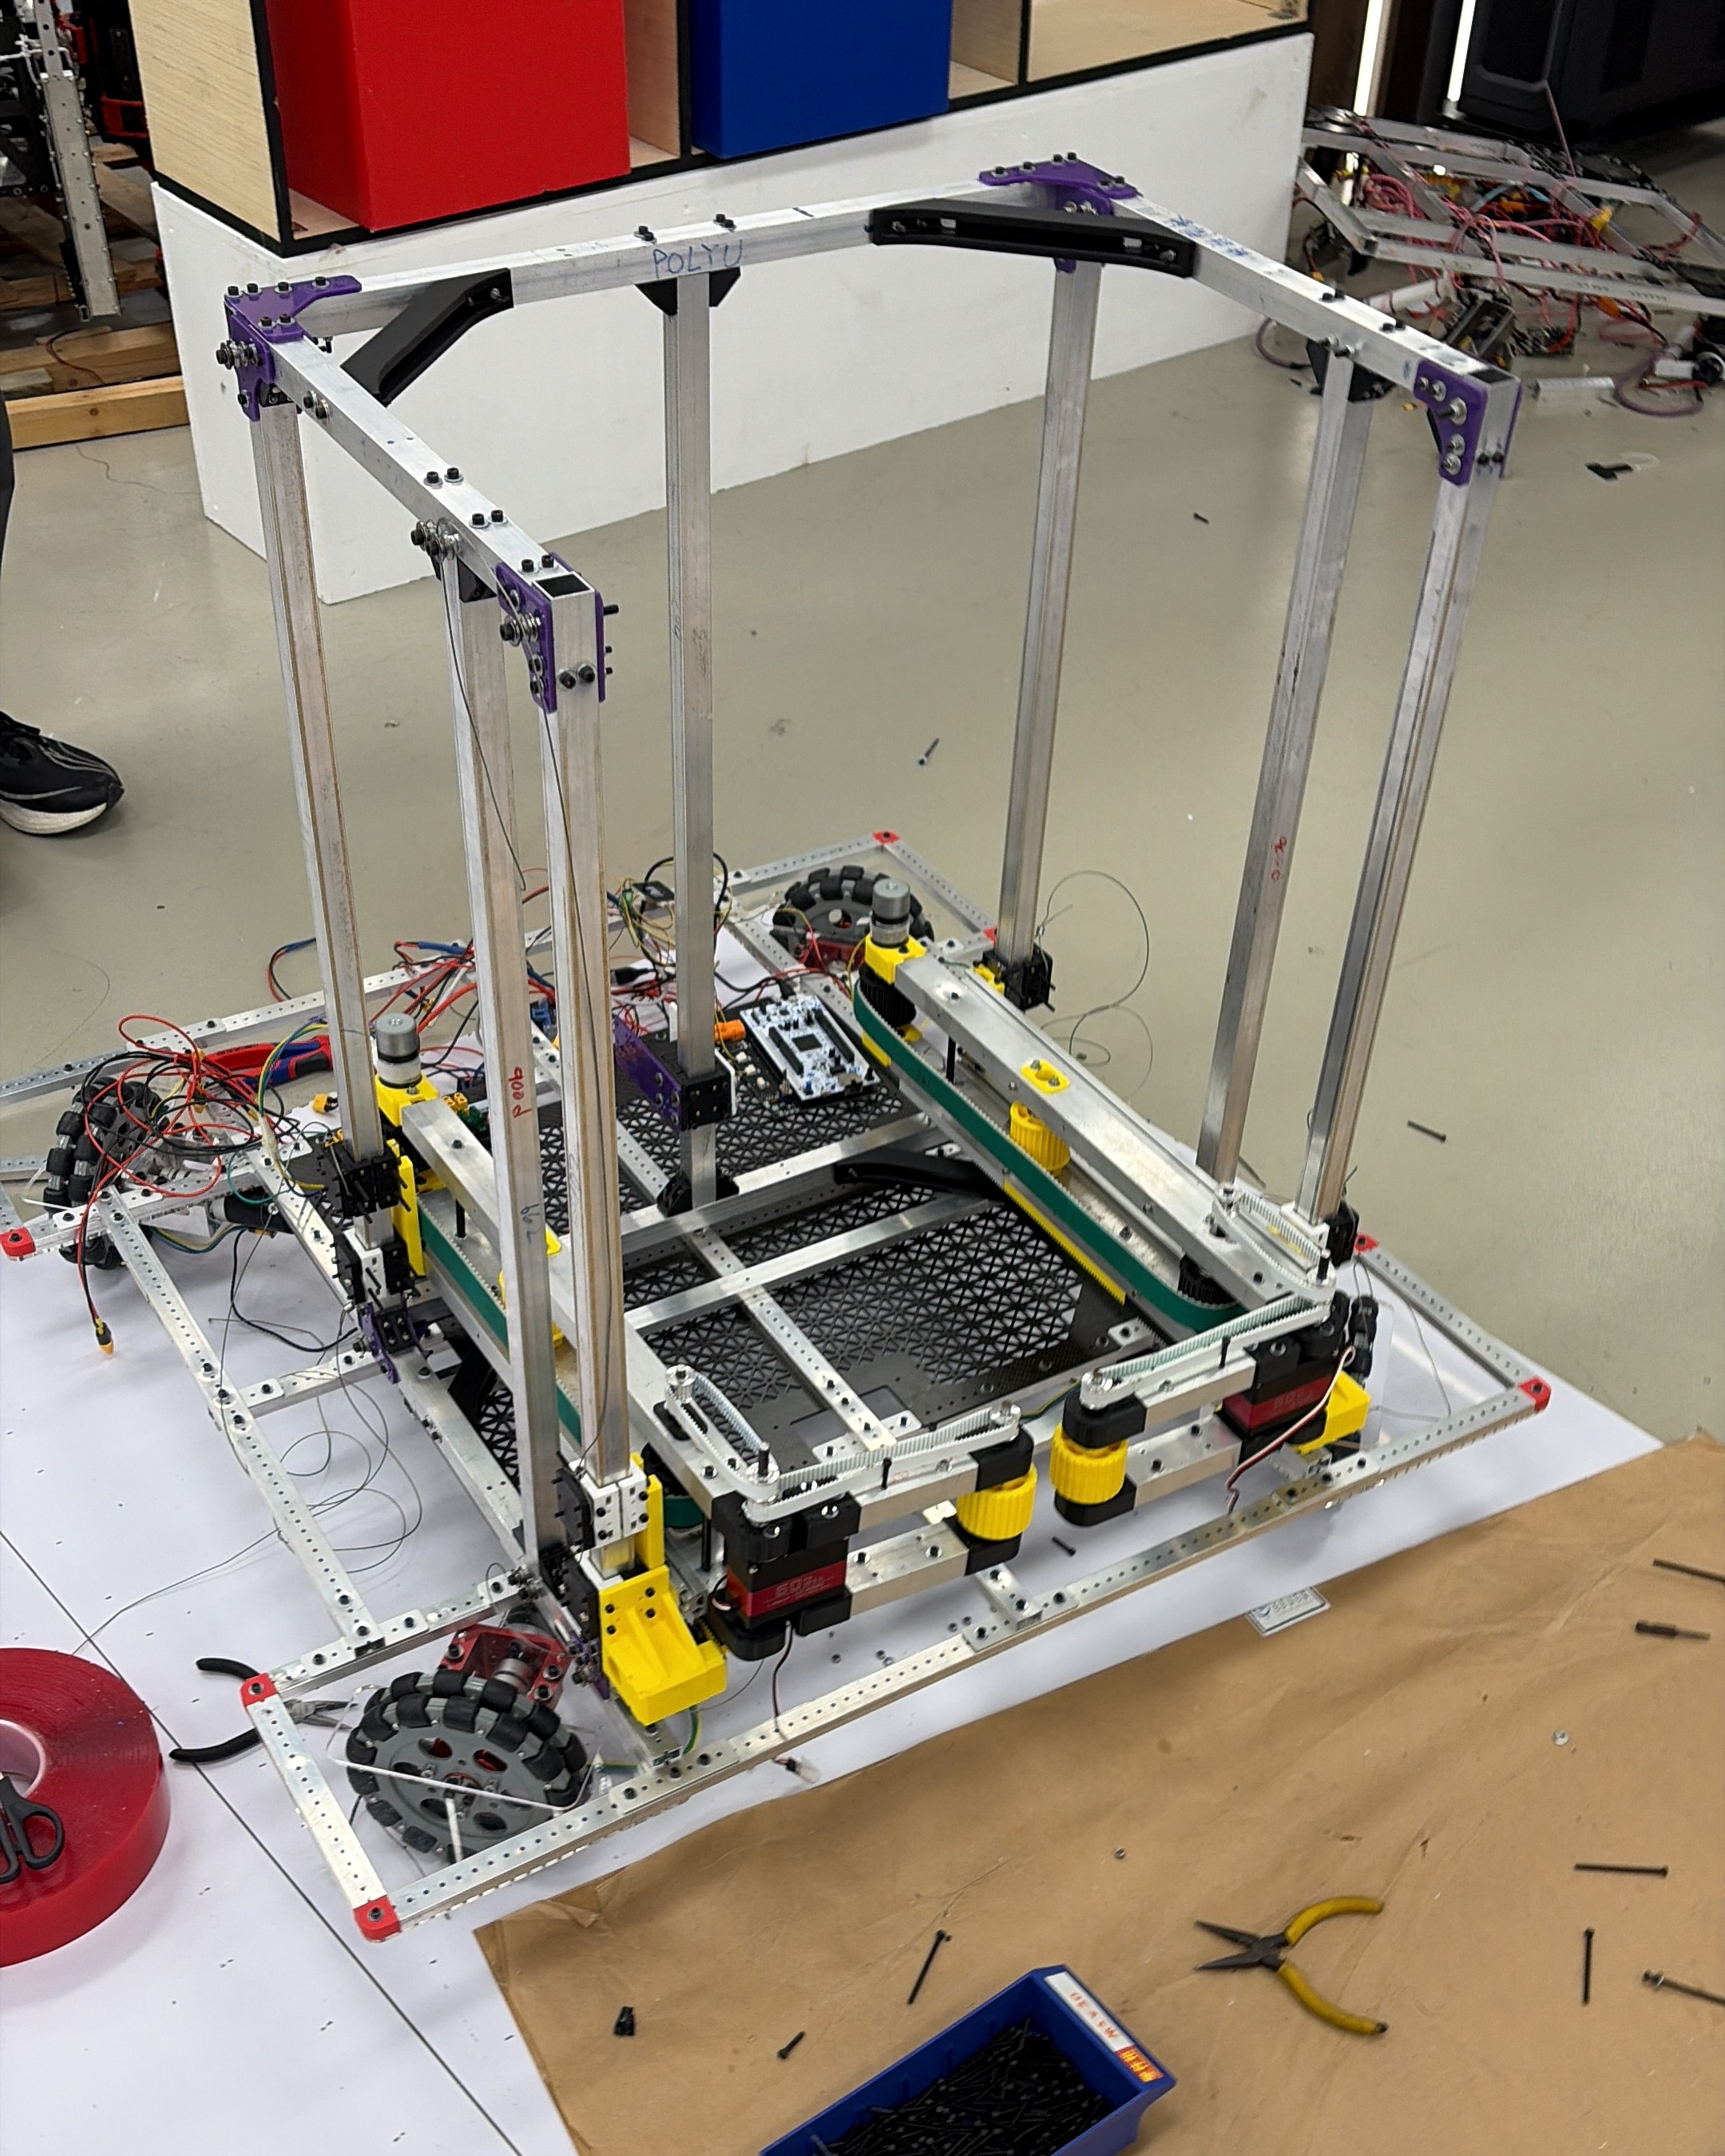
Mechanical designer on The Hong Kong Polytechnic University's Redbricker team for the ABU Asia-Pacific Robot Contest (Robocon 2026, Hong Kong). I led the design of Team 2's manipulator and designed Team 1's telescopic-arm extension.
- 2-segment manipulator — a front variable-angle conveyor and a rear fixed conveyor, linked so they move together, built for Team 2
- Telescopic-arm extension — designed for Team 1
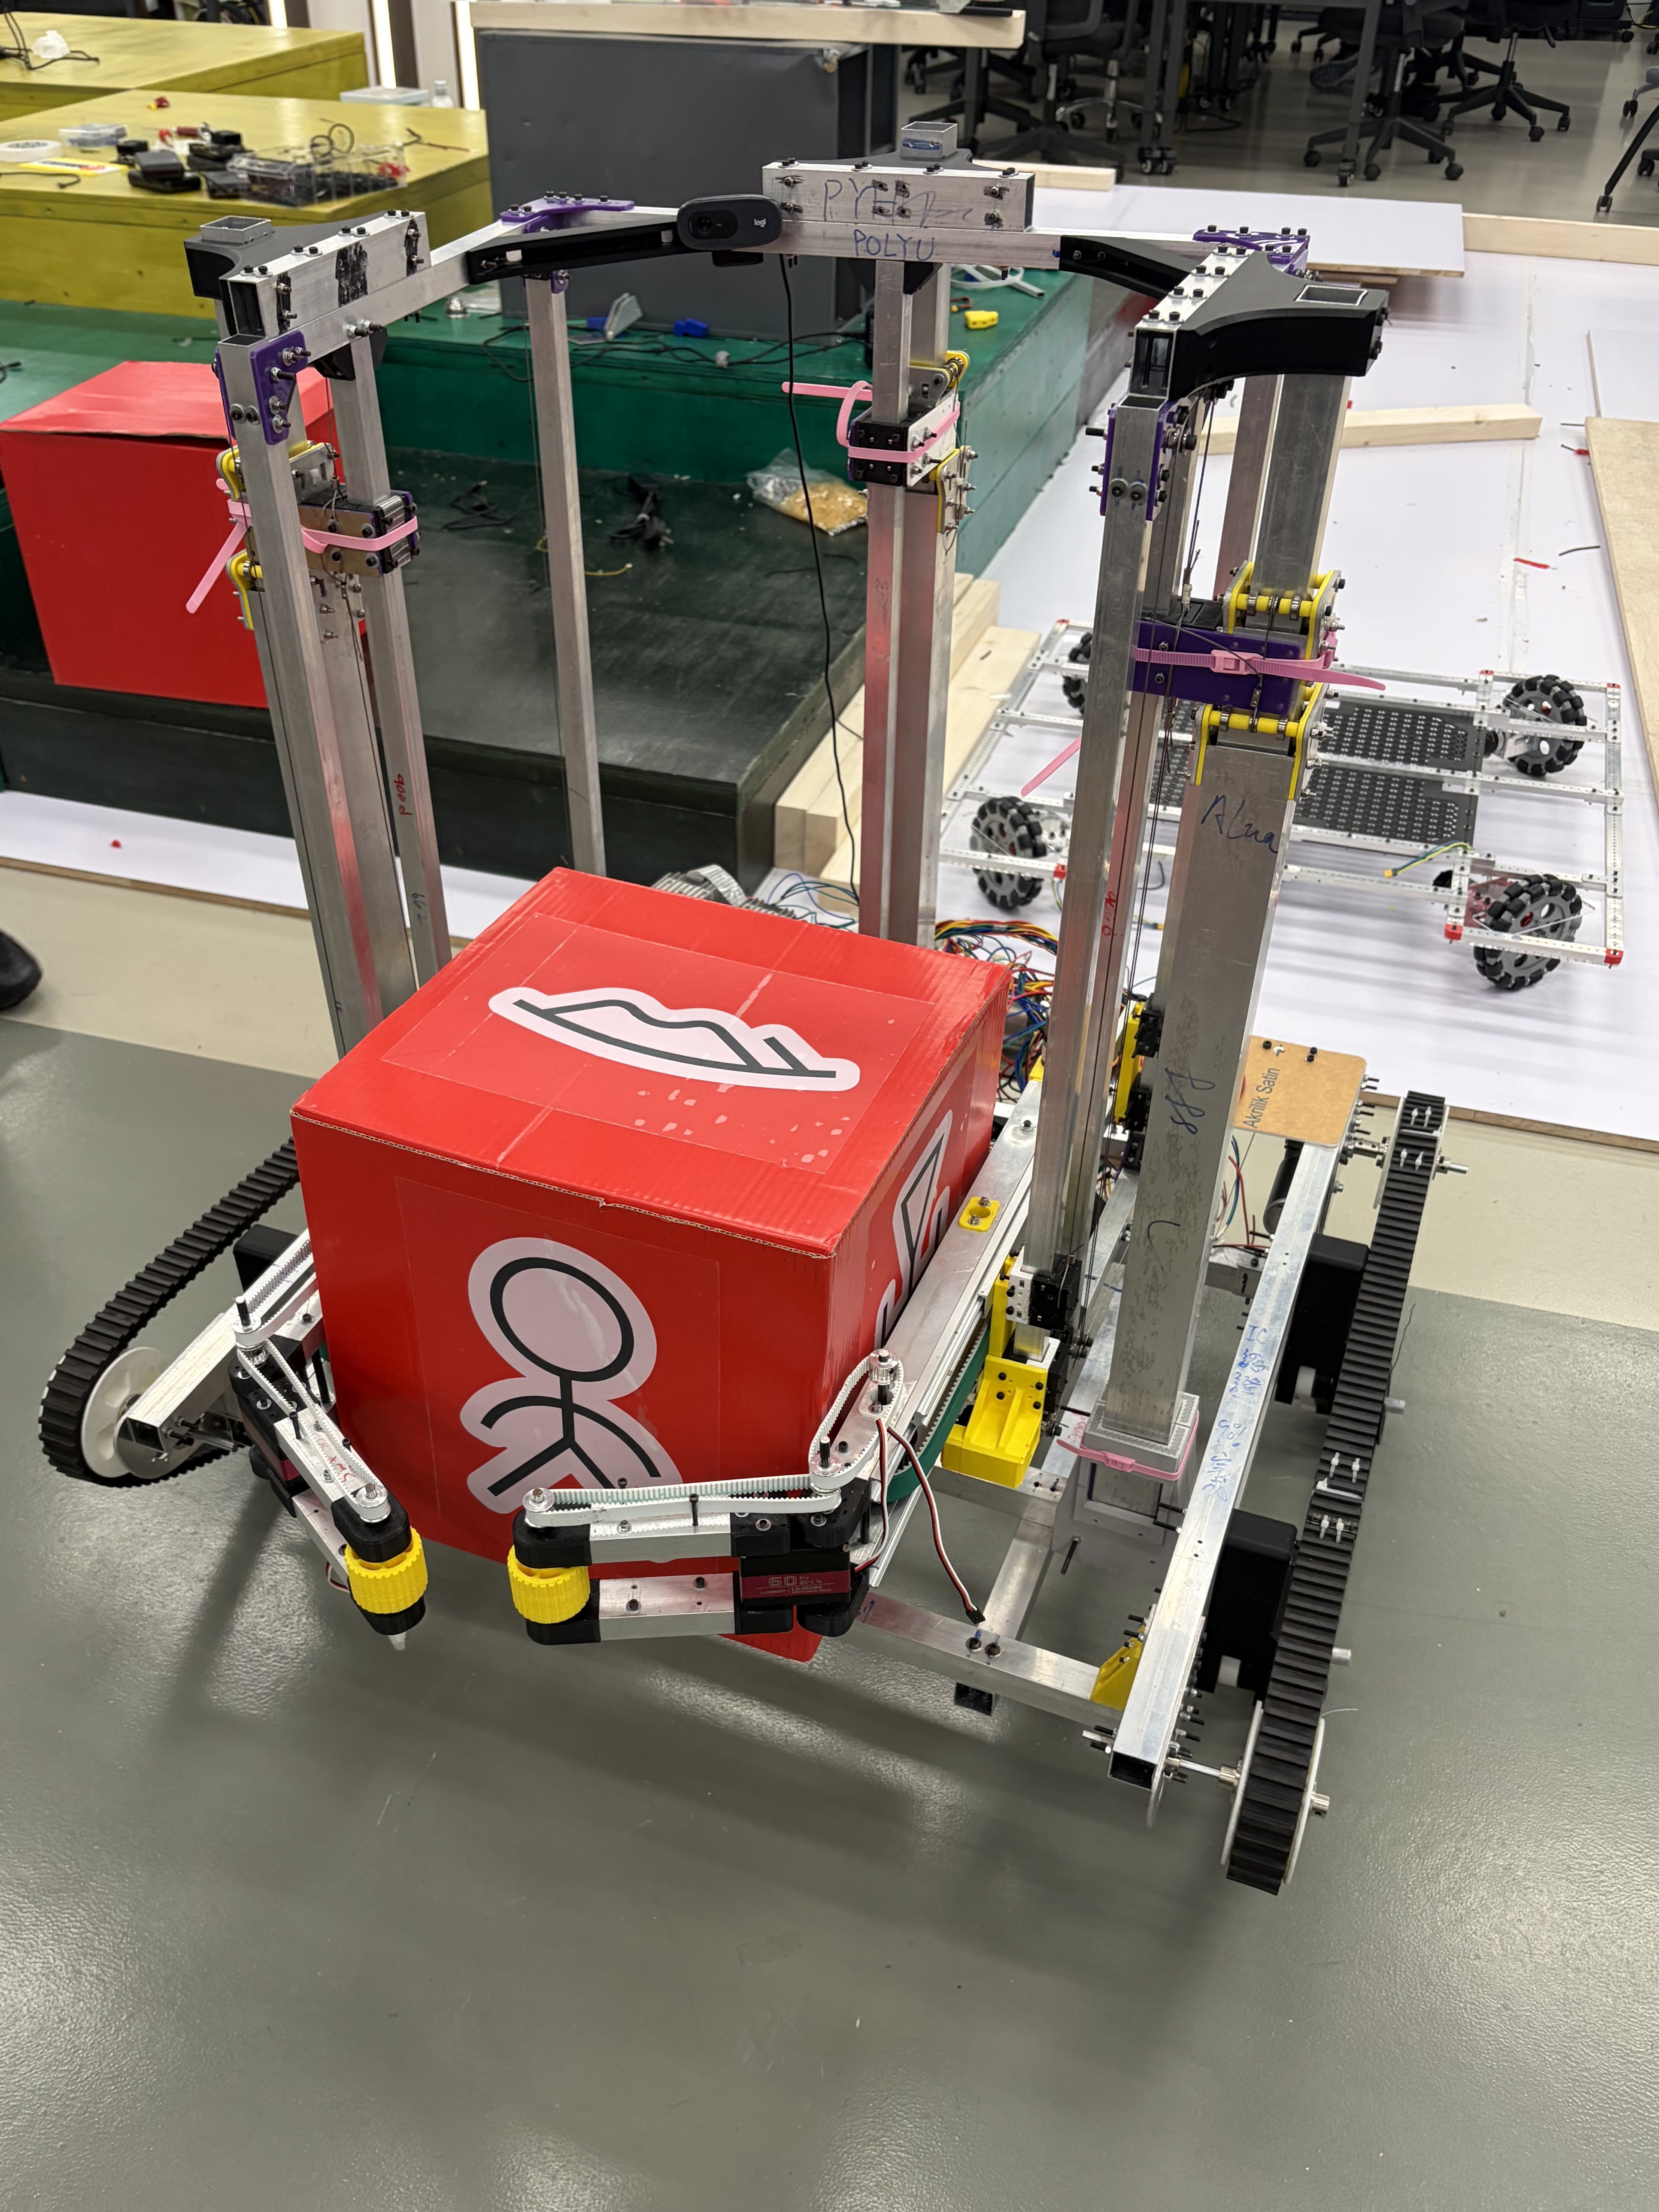
- The competition platform itself, reworked from a robot I had already built for my IC382 course
This robot started life as my IC382 coursework. Rather than design from scratch, I stripped that machine down, reworked the chassis, and built the lift and manipulator systems onto it — turning a course project into a competition platform. That's why I know every part on it.
It also taught me the limit of mechanics. I finished the arm and then watched it sit there — a mechanism with nobody to drive it. That gap is what pushed me to learn motors and electronics, which became the next two projects.
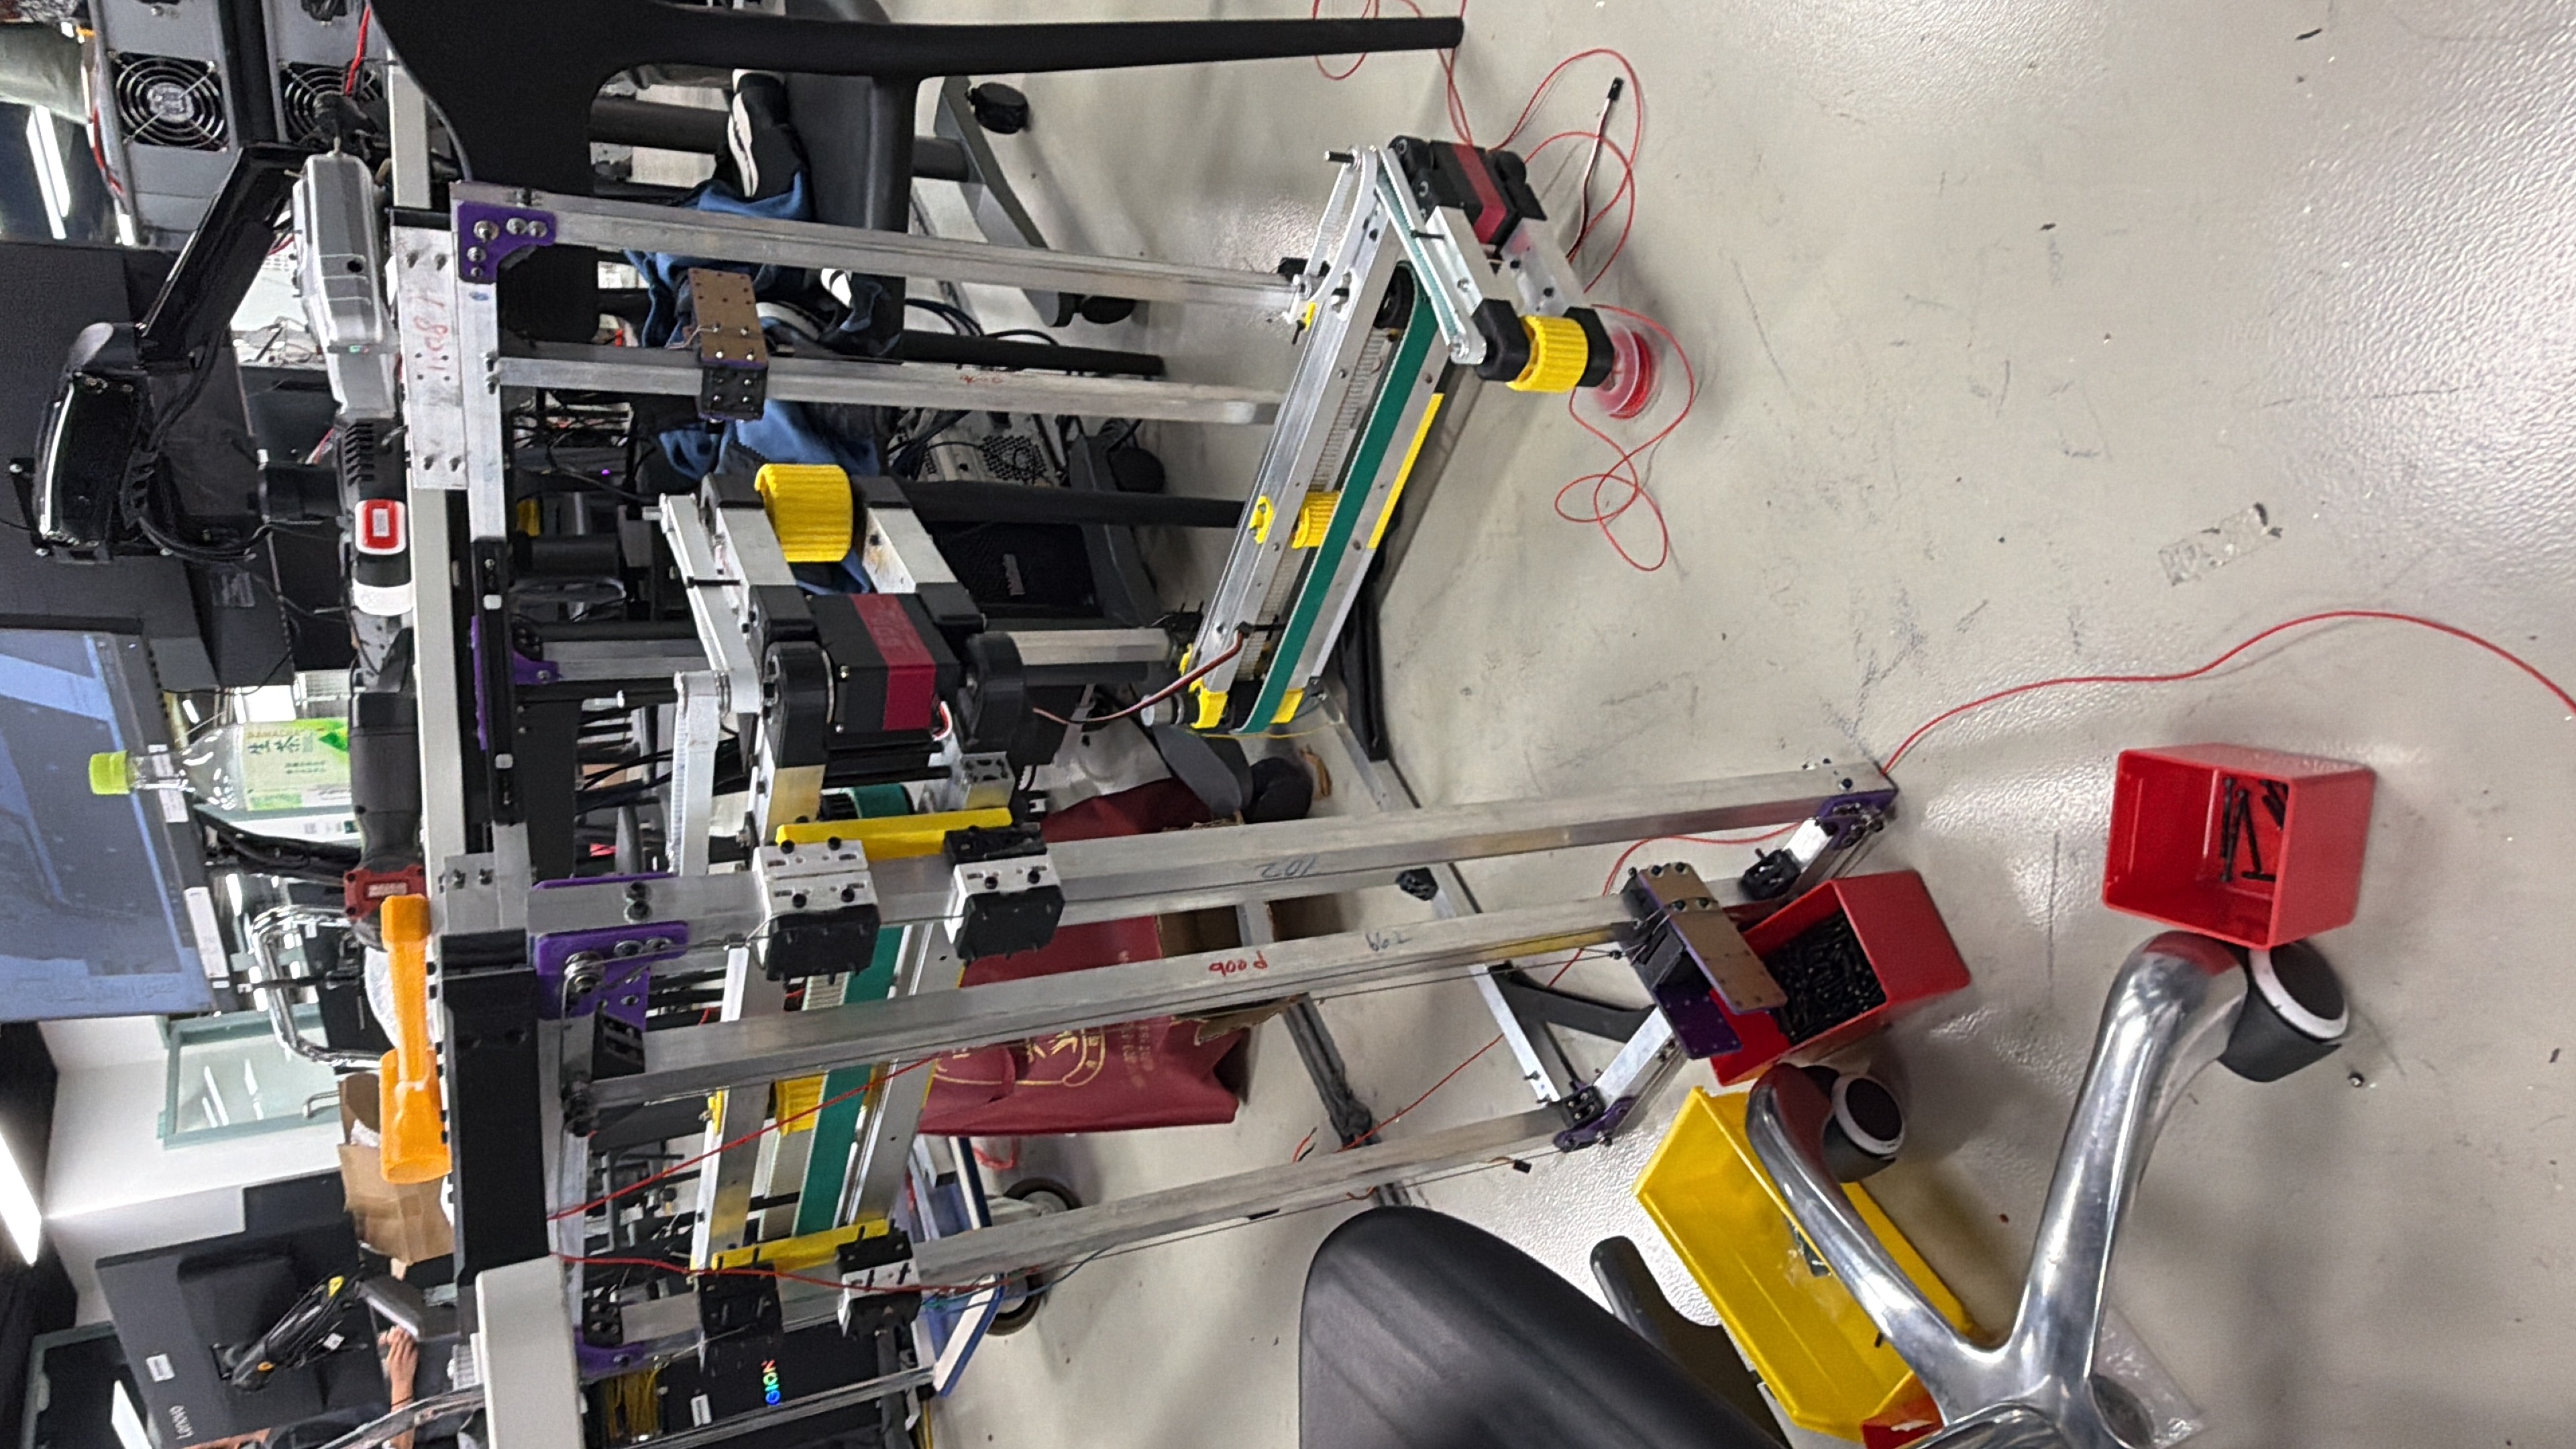
Competed at Robocon 2026 (Hong Kong) as part of Team 2, Redbricker.